Hi,

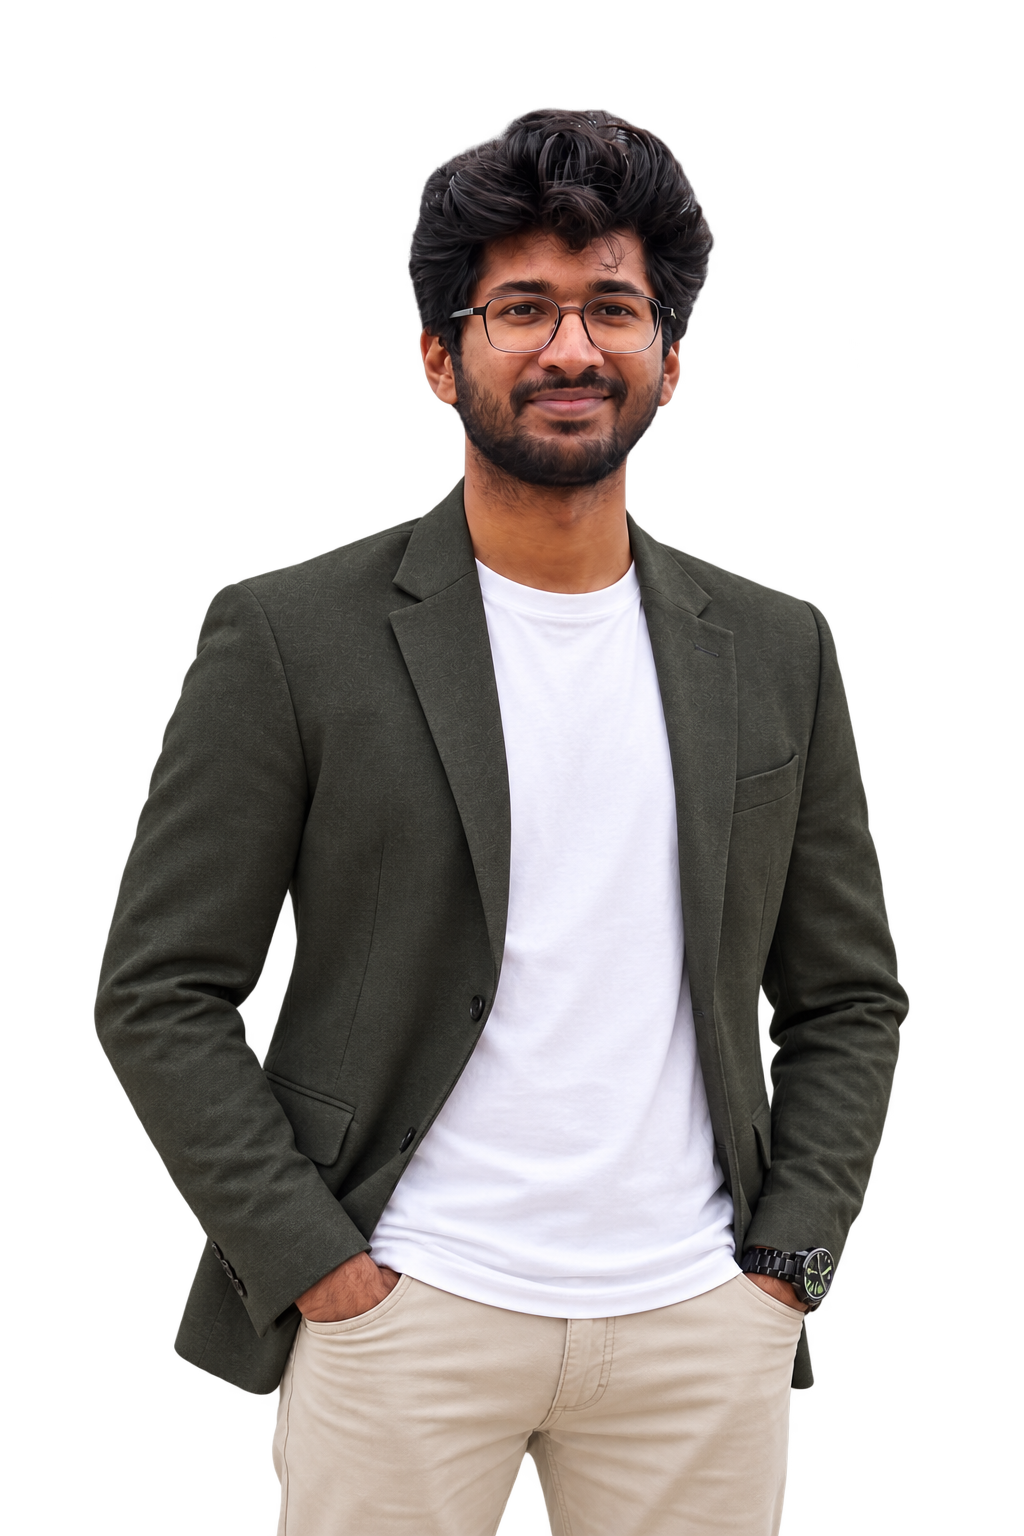
I'm Vivek

Mechatronics Engineer

5+ years of work experience

Vivek Hari

Based in Germany

Specializing in

simulation-driven development,

robotics,

real-time 3D &

engineering workflow automation.

Bridging simulation, robotics, real-time 3D, and automation to turn engineering data into interactive, production-ready systems.

Let's do something fun!

About Me

Experienced engineer delivering practical, high-impact engineering solutions.

Hello there! I'm Vivek Hari, I just graduated with Masters degree in Mechatronic and Cyber-Physical Systems from Technische Hochschule Deggendorf. Along with my strong foundation in Mechanical Engineering, I bring a wealth of experience to the table. My professional journey spans software development, robotics, finite element analysis, workflow automation (CAE, CAD and XR) and AR/VR application development, showcasing a blend of technical expertise and practical application in multi-disciplinary domains.

I am driven by a relentless passion for innovation and a commitment to staying at the forefront of cutting-edge technologies. My career has been marked by a series of initiatives that reflect my dedication and hard work, and I thrive on opportunities to learn and grow in dynamic environments.

My background includes leading diverse teams in both academic and professional settings, and I am confident that my extensive experience and technical acumen will be a valuable asset to any organization, and I look forward to contributing to future successes and advancements.

In my spare time, I like to ride a bicycle, go on long walks, play video games, and watch motorsports especially F1, I love Formula One racing so much that I might just look at you blankly if you mention any other racing series. But hey, I'm game for any new motorsport experience!
Programming Languages

Python C++ C# MATLAB Bash Swift TCL/TK

CAE

Abaqus Altair Hyperworks Altair Hypermesh Altair Hyperstudy Ansys Autodesk Fusion 360 MSC Patran

CAD

SOLIDWORKS CATIA V5 AutoCAD Blender

Game Engine

Unity Unreal Engine Godot

System Modelling

Simulink

Robotics

ROS 1 Noetic SLAM URDF AMCL Navigation Gazebo Moveit Movebase

AI & Tools

Prompt Engineering Github Copilot Cursor Antigravity

Machine Learning

PyCaret Pandas NumPy SciPy Matplotlib Seaborn

Computer Vision

OpenCV PyTorch

DevOps & Tools

Jira Azure Git Docker n8n CI/CD CMake User Story Creation Agile/Scrum

IDEs

VS Code Jupyter Notebook Spyder Pycharm

Operating System

Windows Ubuntu

Documentation

Confluence Latex MS Powerpoint MS Excel MS Word

My Journey

From India to Germany, pursuing my passion for mechatronics engineering.

After completing my Bachelor's in Mechanical Engineering from TKMCE and accumulating valuable 4 years of R&D experience at MRF Tyres in India, I decided to chase my passion for Mechatronics in Germany. This led me to pursue a Master's degree in THD and take up challenging roles at CARIAD and BMW Group, where I continue to grow and build innovative solutions using simulation-driven development, spatial computing and automation.

TKMCE
2015-2019
MRF Tyres
2019-2023
THD
2023-2026
CARIAD
2023-2024
BMW Group
2024-2025

B.Tech Mechanical Engineering

TKM College of Engineering

Aug 2015 - Jul 2019

Education

March 2023 - March 2026

M.Eng in Mechatronic and Cyber-Physical Systems

Technische Hochschule Deggendorf

Cham, Germany

Core Courses: Advanced Modelling and Simulation, Virtual and Augmented Reality, Cooperative and Autonomous Systems, Human Machine Interface, Additive Manufacturing, Cyber Physical Systems, Functional Safety

Grade: 1.7

Thesis: Workflow Development and Automation for Prototyping Vehicle Interiors using Extended Reality

August 2015 - July 2019

B.Tech (Honours) in Mechanical Engineering

TKM College of Engineering

Kollam, India

Core Courses: Automotive Engineering, Engineering Mathematics, Engineering Mechanics, Fluid Mechanics, Mechanics & Dynamics of Machinery, Metrology and Instrumentation, Mechatronics, Design of Machine Elements

Grade: 2.0

Thesis: Design and Structural Analysis of a Below Knee CFRP Prostheses

Professional Experience

October 2024 - November 2025 [8 Months]

Master Thesis Student, XR Software Developer - Workflow Automation

BMW Group

Garching bei München, Germany

  • XR Workflow Design: Designed and validated a complete XR workflow for vehicle interior prototyping using Blender, Unity, and Apple Vision Pro, addressing key challenges in immersive model visualization.
  • Application Development: Developed two interconnected Unity applications, the XR Viewer and XR Controller, which facilitates interactive visualization and multi-user collaboration in shared mixed-reality environments.
  • Automated Scene Creation: Created an automated model import and configuration system in Unity, utilizing scriptable objects and Unity’s serialization methods to streamline scene setup, material and event/UI-driven animation assignments without manual intervention.
  • Model Preparation Guidelines: Developed a custom Blender add-on to standardize model structuring, animation setup, and material assignment, ensuring seamless integration with the Unity automation tool.
October 2024 - March 2025 [6 Months]

Working Student, XR Software Developer

BMW Group

Garching bei München, Germany

  • XR Application Development: Spearheaded the development of an XR application in Unity for Apple Vision Pro and Meta Quest 3, implementing advanced interactive and shader techniques, considering the performance for real-time interactions.
  • C# Scripting: Engineered OOPs based C# components in Unity to manage precise model spawning over markers, create dynamic UI elements, and enable real-time material swapping, ensuring a highly interactive user experience.
  • Multiplayer Collaboration: Designed and implemented a multiplayer collaboration system that allows multiple users to interact with the same virtual model in real-time, utilizing Unity's Netcode for GameObjects for networking and seamless connectivity.
  • User Experience Testing: Led rigorous testing cycles, gathering and incorporating user feedback to enhance the application’s usability, demonstrating a commitment to user-centered design principles.
  • Arduino Development: Real-time physical seat rotation tracking using an ESP32 with BMI270+BMM150 9-axis sensors, streaming orientation data via Wi-Fi (UDP) to a Unity XR application on Apple Vision Pro for seamless physical-to-virtual seat synchronization with a low-cost, scalable modular setup.
June 2023 - May 2024 [1 Year]

Working Student, ADAS/AD Function Development - Safety & Validation

CARIAD SE

Ingolstadt, Germany

  • Research and Compliance: Conducted in-depth research on laws and regulations governing autonomous driving systems, utilizing resources such as government publications and industry standards to ensure compliance with legal frameworks (e.g., ISO 26262, ISO21448).
  • Scenario Development: Employed the Pegasus methodology to document a range of driving scenarios, facilitating rigorous testing of software components to enhance robustness and reliability. Utilized tools like MATLAB for simulations and data analysis.
  • Model Implementation: Successfully implemented the Constant Yaw Rate and Acceleration (CYRA) motion model in MATLAB, enabling precise simulation of vehicle dynamics under various conditions.
  • Code Optimization: Reworked Python code for calculating metrics related to criticality analysis methods, employing libraries such as NumPy and Matplotlib to visualize data, thus improving performance by 35% and enhancing code reusability.
  • Criticality Analysis: Conducted detailed comparisons of criticality analysis methods, employing statistical techniques to assess their applicability and performance in different driving scenarios. Documented results in comprehensive reports for decision-making purposes.
  • Database Evaluation: Investigated the usability of the Common Road Database, evaluating its structure and content to support future decision-making on its integration within the autonomous driving framework.
  • Documentation Migration: Assisted in migrating existing software requirements to a new Doc as Code tool (Sphinx-Needs), ensuring compliance with internal policies.
June 2022 - March 2023 [10 Months]

Senior Simulation and Automation Engineer (R&D)

MRF Tyres

Chennai, India

  • Leadership in Simulation: Led the development and validation of advanced simulation methodologies, employing FEA in Abaqus CAE to evaluate tyre characteristics and performance metrics.
  • Model Optimization: Designed and simulated over 100 tyre models, utilizing optimization algorithms to enhance traction, durability, and energy efficiency (Rolling Resistance), and conducting sensitivity analysis to validate results.
  • CAE Workflow Automation: Managed automation of end-to-end simulation workflows using Python and batch scripting, integrating libraries such as Pandas, Matplotlib and NumPy for data handling and analysis, which reduced FEA turnaround time by over 70%.
  • Design of Experiments: Cut design-parameter iteration time by 98% by implementing machine-learning-based prediction (PyCaret) and Design-of-Experiments frameworks using Hyperstudy around the simulation workflow.
  • Cross-Functional Collaboration: Worked closely with manufacturing teams to validate simulation data through indoor tyre tests of over 100 tyre models, enhancing the reliability and accuracy of the simulation framework.
September 2019 - May 2022 [2 Years 9 Months]

Simulation and Automation Engineer (R&D)

MRF Tyres

Chennai, India

  • Simulation Development: Assisted in developing and validating advanced simulation methodologies using Finite Element Analysis (FEA) principles in Abaqus CAE, applying mesh refinement techniques to ensure accurate results for static and dynamic tyre characteristics.
  • Model Creation: Created high-fidelity 2D and 3D tyre models using CATIA and Altair HyperMesh, employing design-for-manufacturability principles to optimize models for production.
  • Testing Correlation: Collaborated with material and indoor testing teams to correlate simulation results with physical track testing data, using statistical analysis methods to improve model accuracy and overall tyre performance.
  • CAD Automation: Automated CAD modeling workflows using CATIA VBA scripting, which reduced repetitive modeling efforts by 78% and improved design team efficiency.

Academic Projects

Innovative and research projects done during my academic career

VR Workshop for Safety Training
VR/AR Game Development Android

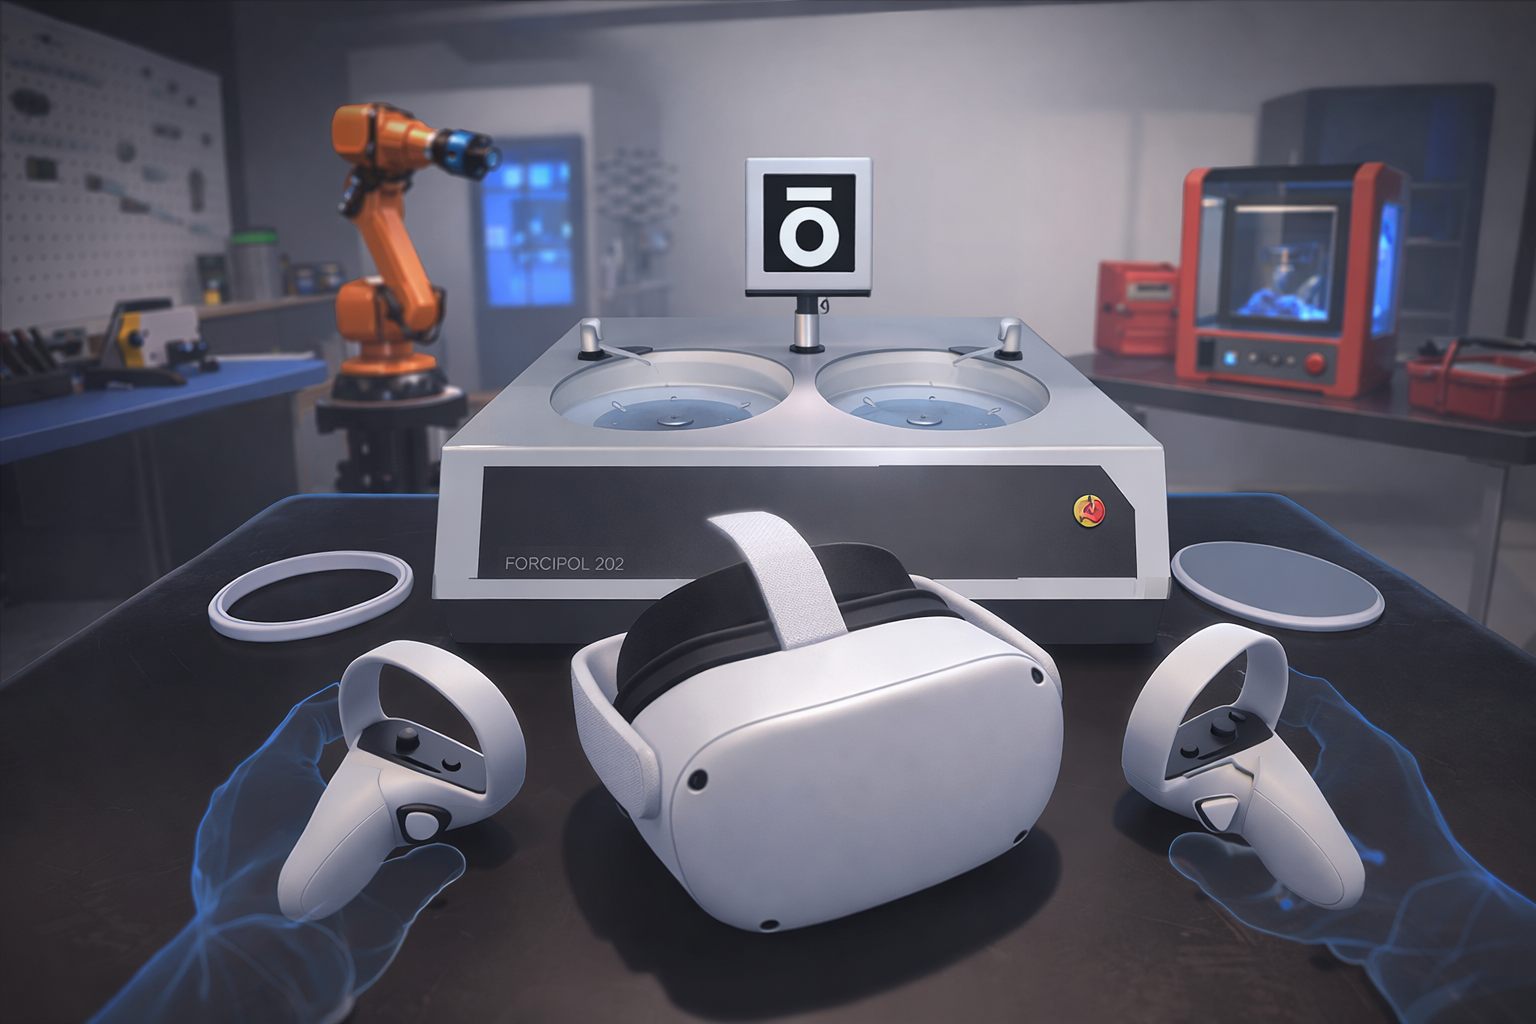
VR Workshop for Safety Training

Immersive VR safety training that enforces a step-by-step workflow before allowing industrial machine operation.

Key Features:

  • Mandatory 12-step safety flow with controlled progression.
  • PPE enforcement requiring gloves and protective eyewear.
  • Machine start disabled until all safety checks are completed, with full control simulation.
  • Hands-on material grinding, microstructure analysis, and restartable training mode.
Unity C# Android SDK Meta Quest 2 Blender
Autonomous Vacuum Bot in ROS
Robotics AI/ML Computer Vision CAD

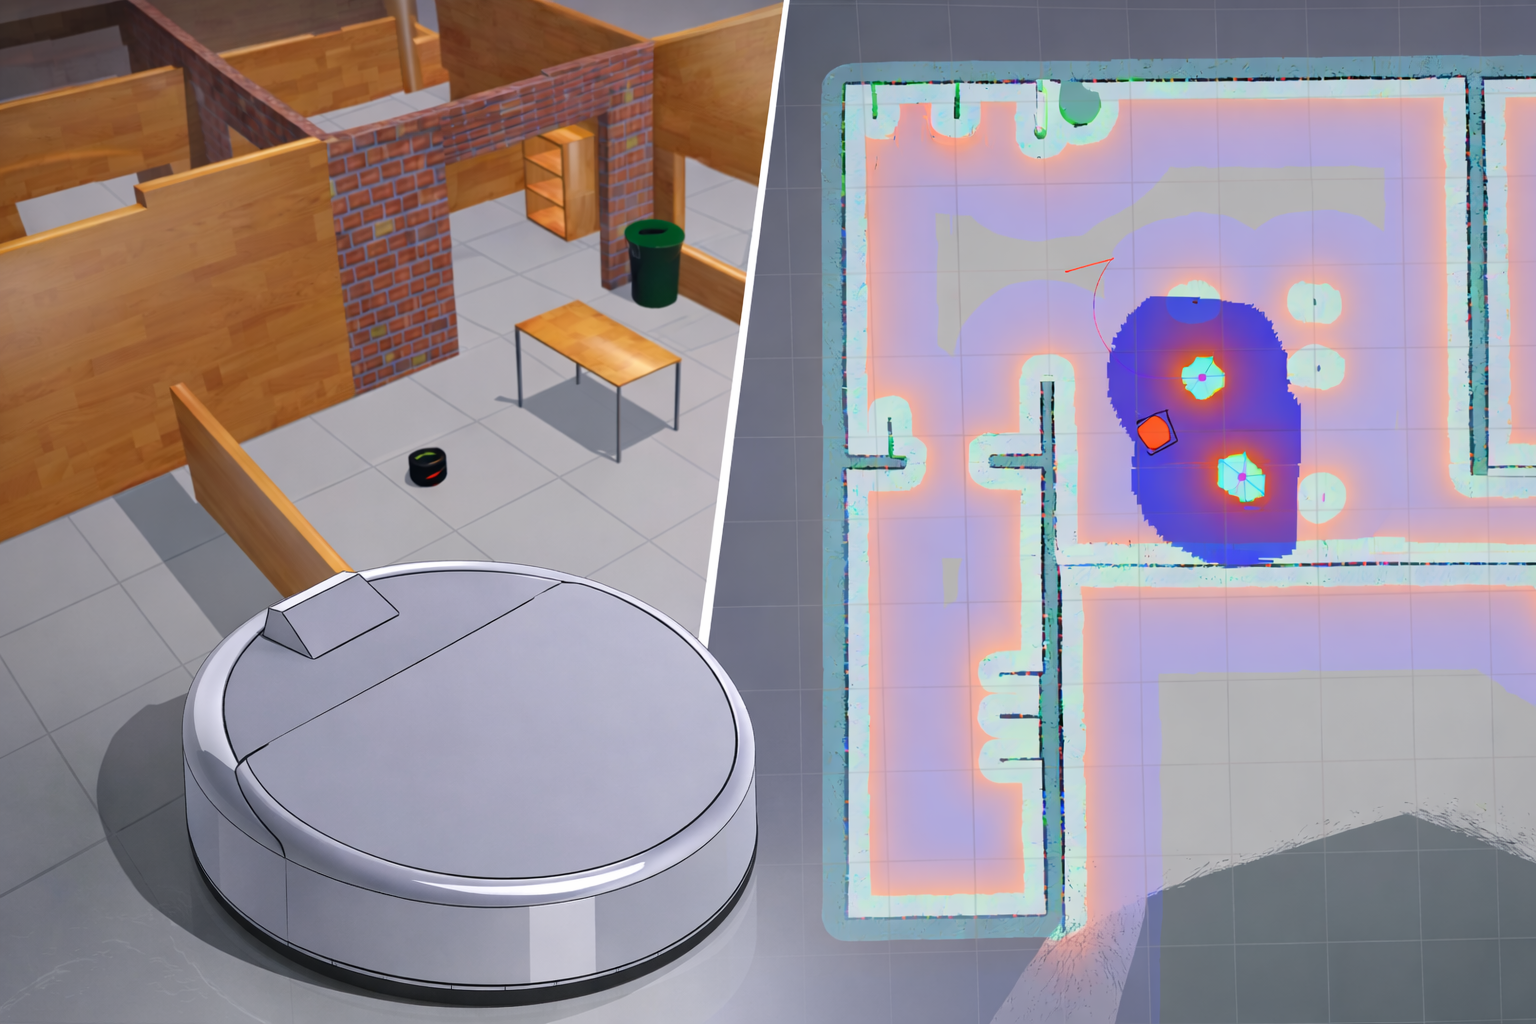
Autonomous Vacuum Bot using ROS

Autonomous vacuum robot developed using ROS that combines SLAM-based navigation, efficient path coverage, and real-time object tracking for intelligent cleaning.

Key Features:

  • End-to-end robot design workflow from SOLIDWORKS to ROS using URDF.
  • Depth-camera-based SLAM for real-time mapping and obstacle avoidance.
  • Autonomous navigation simulated in Gazebo using move_base and AMCL.
  • Systematic area coverage with integrated path planning and OpenCV-based object tracking.
ROS Gazebo D-RGB Camera LIDAR YOLO URDF SOLIDWORKS
Topology Optimization of a Temporary Bag Sealer for Additive Manufacturingg
CAD CAE Additive Manufacturing

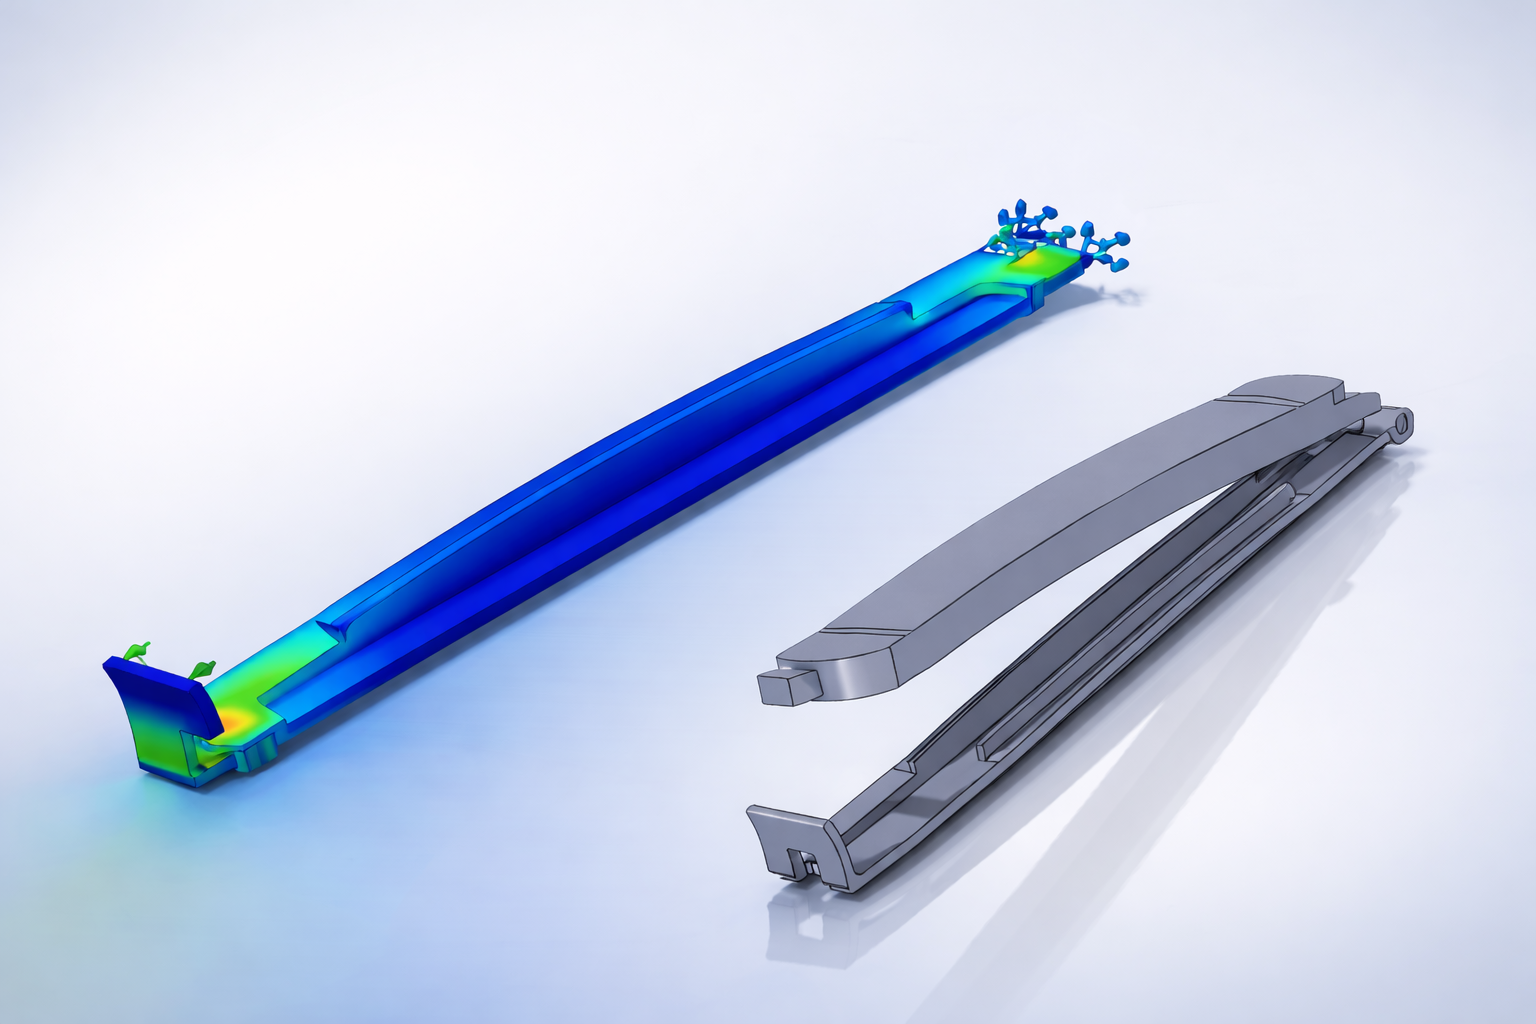
Topology Optimization of a Temporary Bag Sealer for Additive Manufacturing

Topology-optimized design of a temporary bag sealer using SOLIDWORKS Simulation to reduce weight while maintaining structural integrity and functionality, optimized for additive manufacturing.

Key Features:

  • Complete CAD design of a snap-fit temporary bag sealer with hinge-based assembly in SOLIDWORKS.
  • Finite Element Analysis of top and bottom parts under realistic displacement- and force-controlled loading conditions.
  • Topology optimization targeting best stiffness-to-weight ratio with a 40% mass-reduction constraint and stress limits within material yield strength.
  • Final optimized design achieving ~22% weight reduction and validated for FDM manufacturing using PLA.
SOLIDWORKS FEA AutoCAD Design
Modelling and Simulation of an Active Suspension System
Simulation Automation

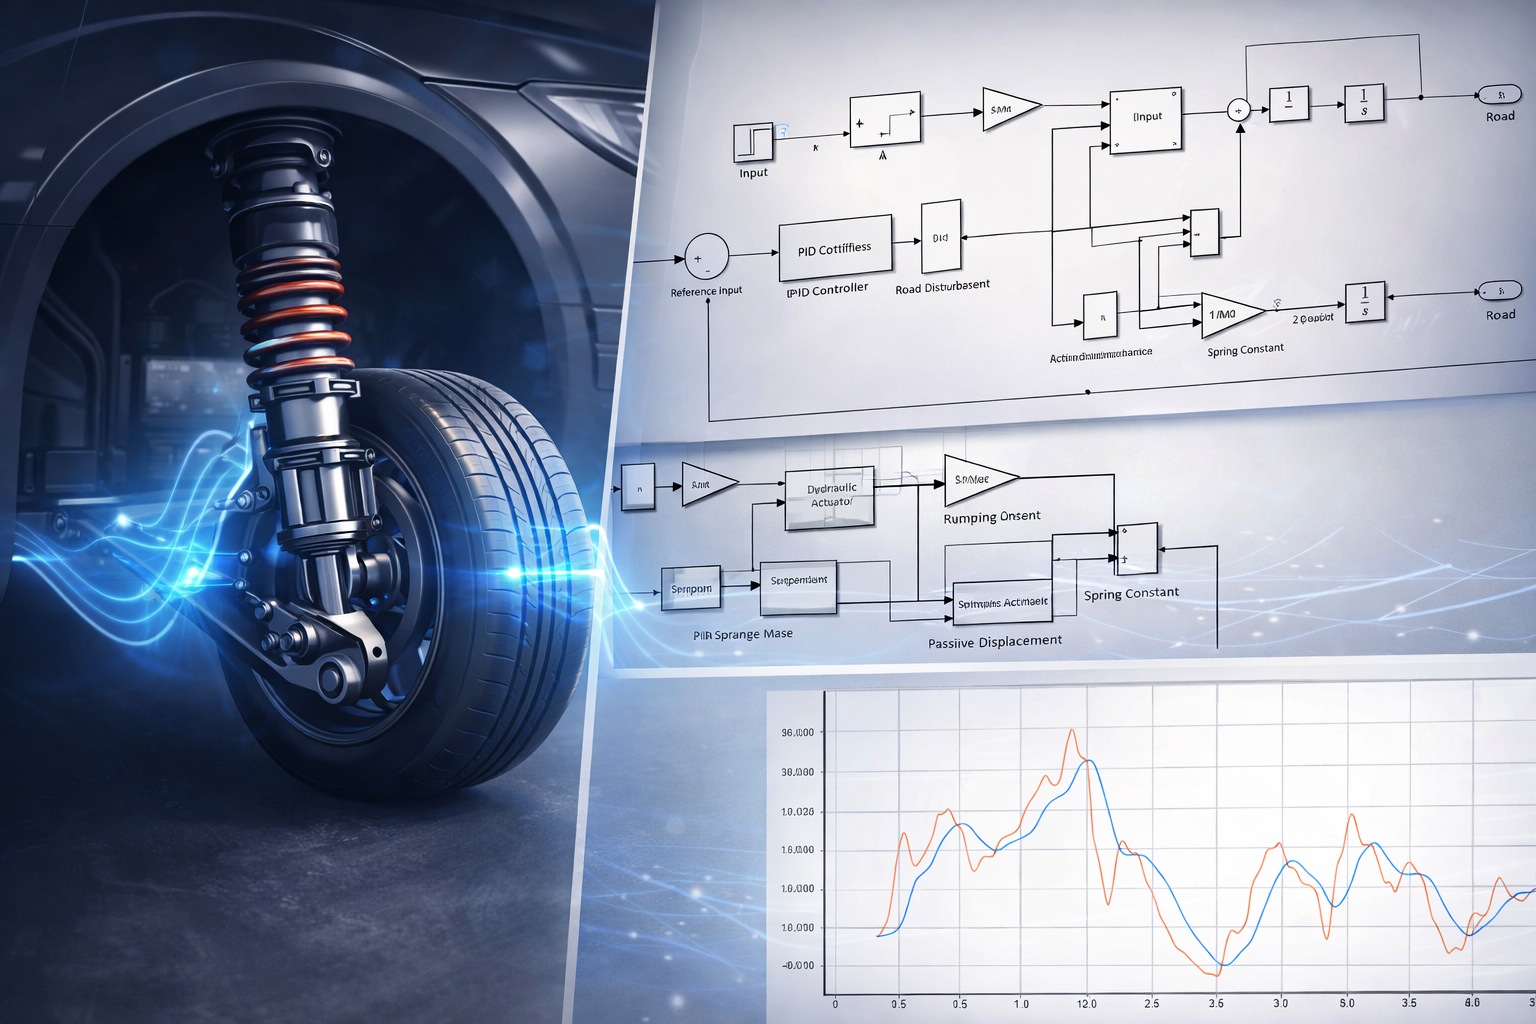
Modelling and Simulation of an Active Suspension System

Modeling and simulation of a PID-controlled active suspension system in MATLAB/Simulink to significantly improve vehicle ride comfort and stability compared to a passive suspension system.

Key Features:

  • Quarter-car active suspension model with hydraulic actuator implemented in MATLAB/Simulink.
  • PID controller design and iterative tuning for step and white-noise road disturbances.
  • Comparative analysis between passive and active suspension systems using displacement, velocity, overshoot, and settling time metrics.
  • Ride comfort evaluation using RMS sprung-mass acceleration, demonstrating clear comfort improvement with active suspension.
MATLAB Simulink System Modelling PID
Design and fabrication of a hybrid three-wheeler trike
CAD CAE Simulation

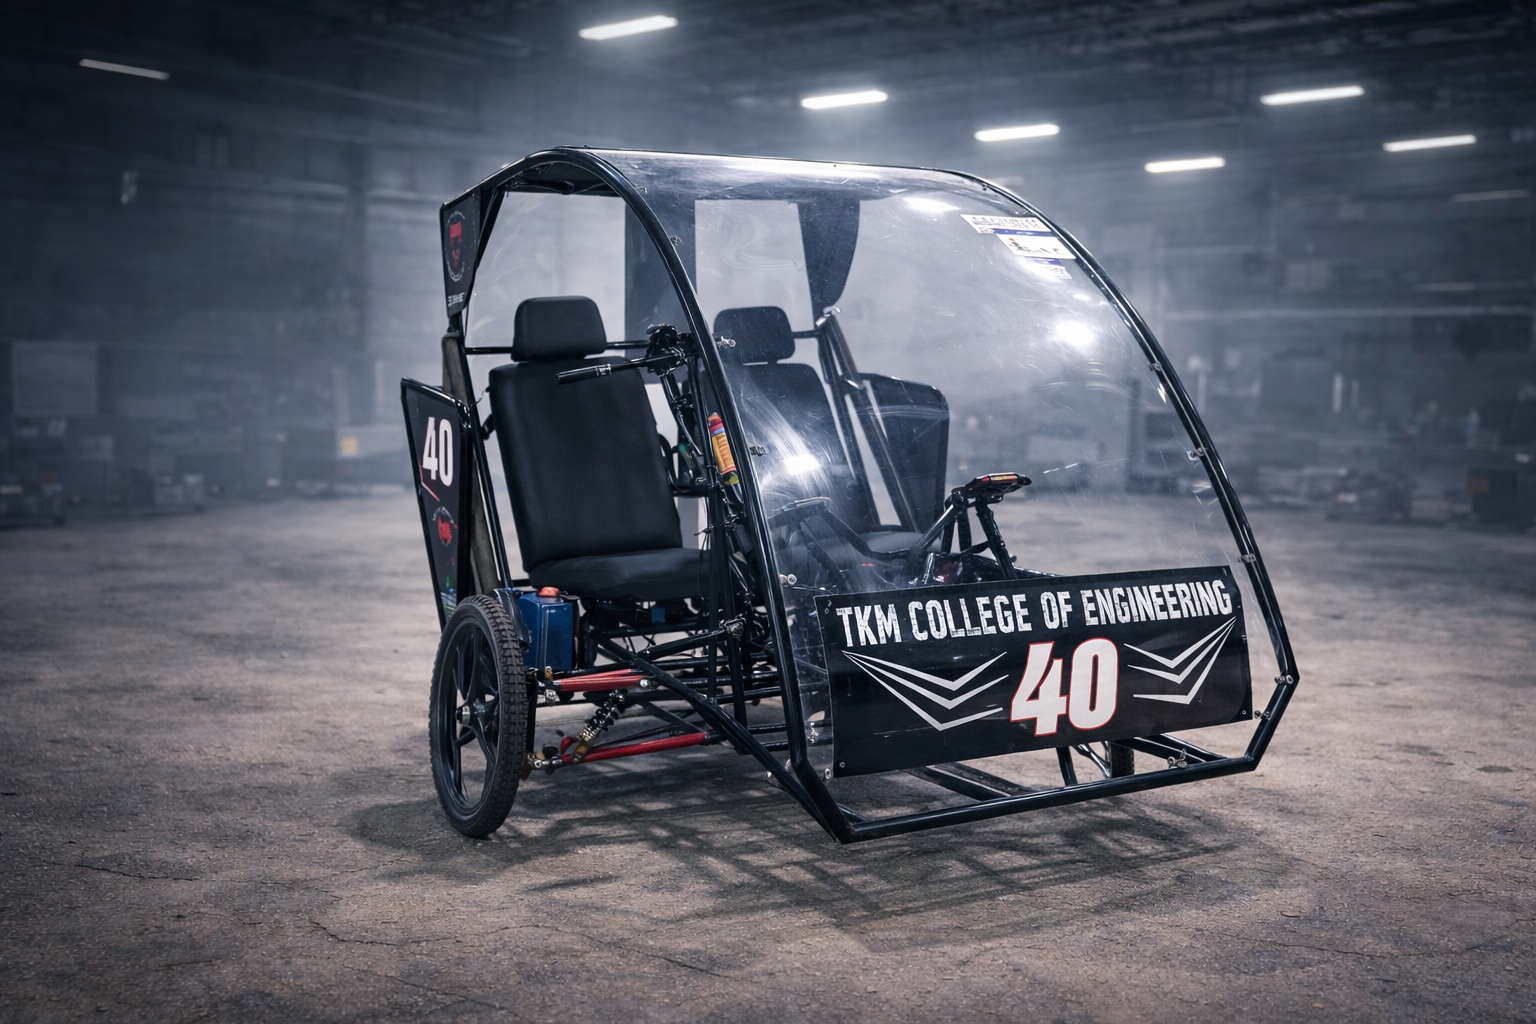
Design and fabrication of a hybrid three-wheeler trike

Design and fabrication of a hybrid three-wheeler trike for SAE NIS Efficycle, focusing on safety-compliant chassis design, efficient hybrid powertrain integration, and full vehicle validation.

Key Features:

  • Safety-driven chassis design with ANSYS simulations for frontal, side, and rollover impacts.
  • Ackermann-based steering and optimized suspension geometry for stable handling.
  • Hybrid powertrain combining mechanical and electric drive through a single shaft with variable ratios.
  • End-to-end fabrication and validation, including welding, assembly, and DVP-based testing.
ANSYS Autodesk Fusion 360 FEA AutoCAD Design
Design and structural analysis of a below-knee CFRP prosthetic foot
CAD CAE Simulation Healthcare

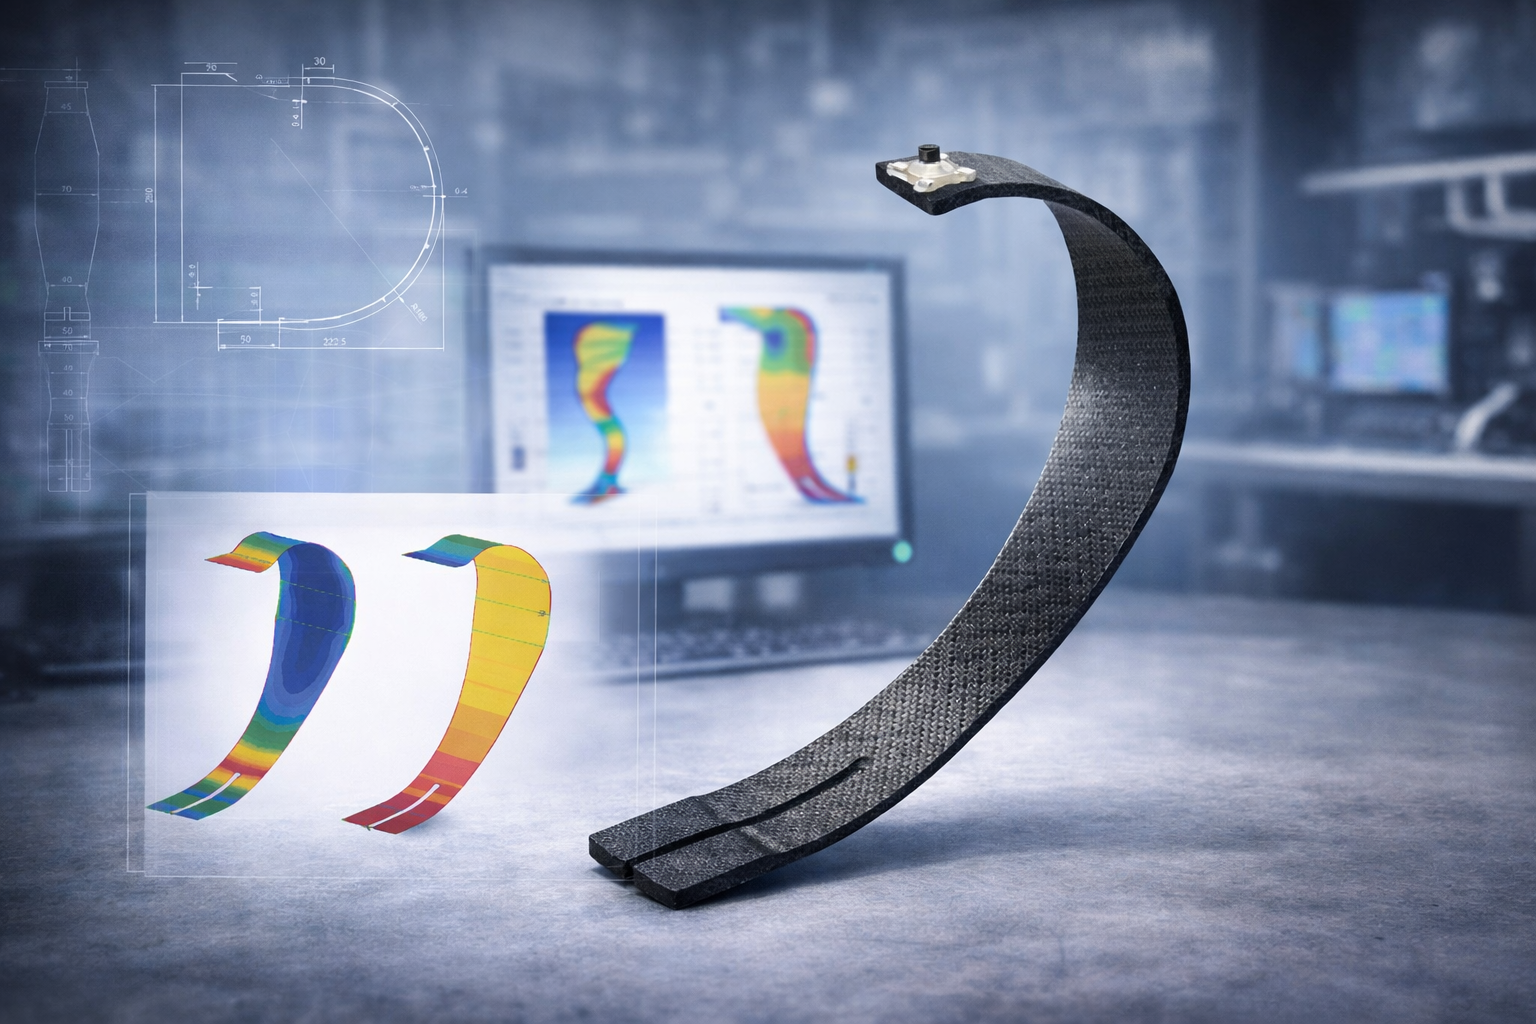
Design and structural analysis of a below-knee CFRP prosthetic foot

Design and structural analysis of a below-knee carbon fiber reinforced polymer (CFRP) prosthetic foot, focused on optimizing stiffness, energy return, and gait performance using parametric modeling and finite element analysis.

Key Features:

  • Parametric prosthetic foot design incorporating human gait biomechanics, energy storage, and impact absorption characteristics.
  • Material selection and laminate orientation study for CFRP to balance stiffness, strength, and weight.
  • Extensive finite element analysis to evaluate stress, deflection, and factor of safety under realistic loading conditions.
  • Comparative evaluation of multiple design variants to improve gait efficiency and structural performance over existing prosthetic models.
MSC Patran Autodesk Fusion 360 FEA SOLIDWORKS AutoCAD Design
Tracking of physical seat rotation using Arduino sensors for XR visualisation
Robotics IOT AR/VR Simulation

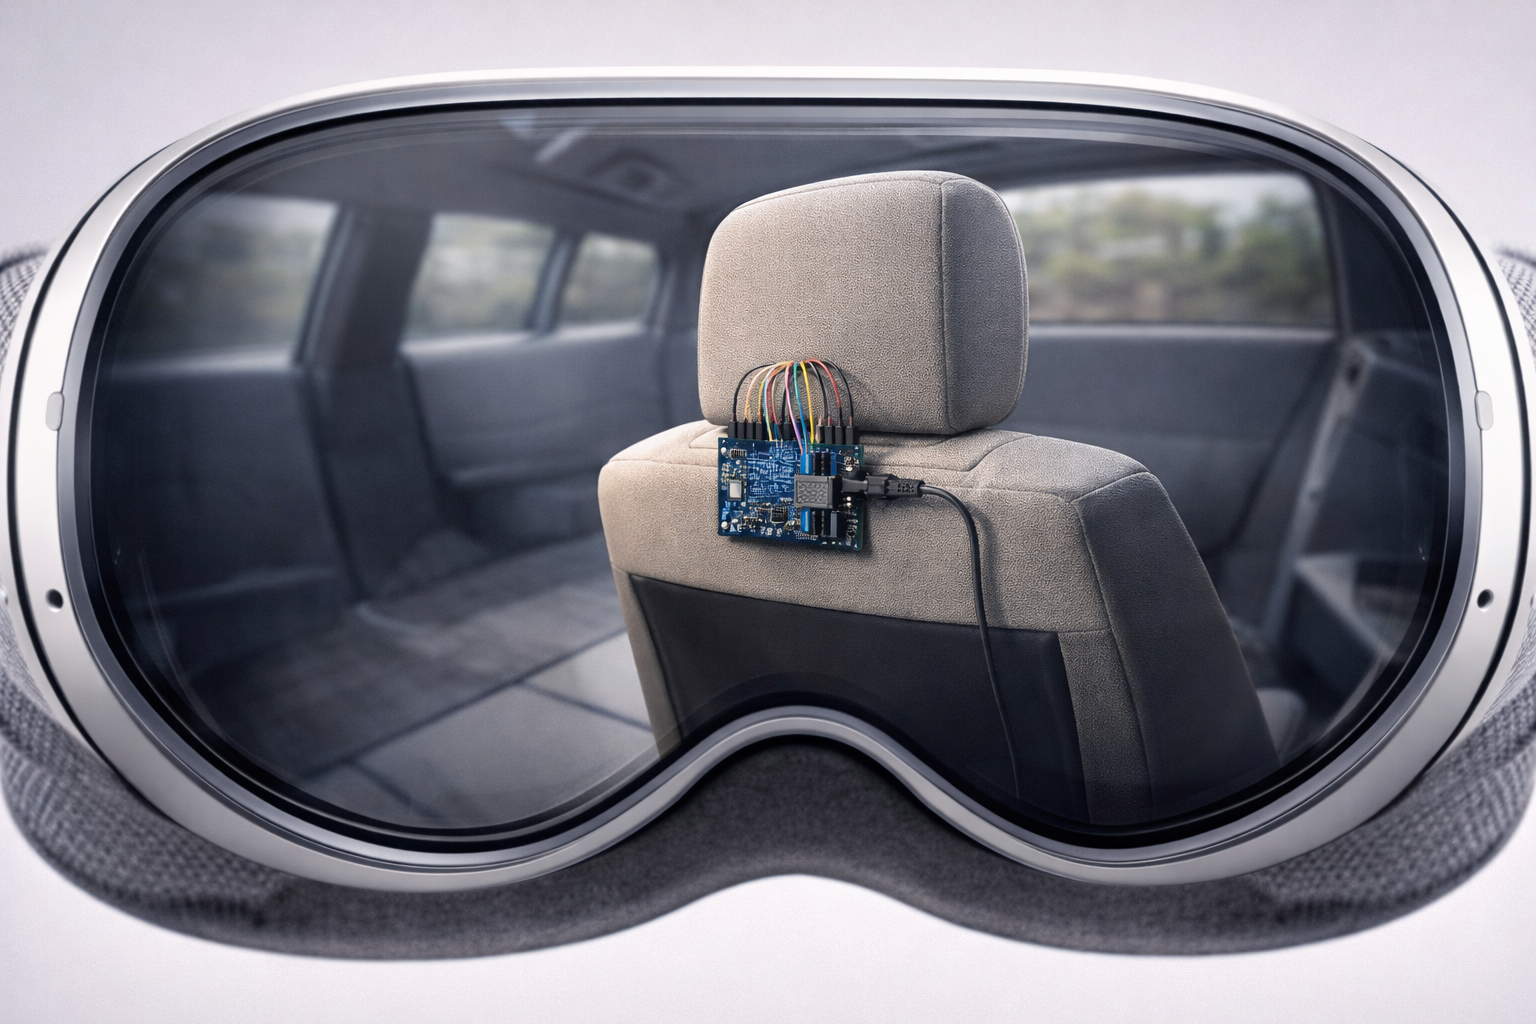
Tracking of physical seat rotation using Arduino sensors for XR visualisation

Real-time tracking of physical seat rotation using arduino sensors and Wi-Fi networking to synchronize motion with a virtual seat inside an XR application on Apple Vision Pro.

Key Features:

  • ESP32 + BMI270 + BMM150 - based 9-axis motion sensing for seat orientation tracking.
  • Real-time data streaming over Wi-Fi using UDP to a Unity XR application.
  • Seamless physical-to-virtual seat synchronization inside VisionOS.
  • Low-cost, modular hardware setup designed for scalable multi-seat integration.
Unity Arduino Networking

Achievements

SAE ISS 2017

Diagrammatic Reasoning - Runner Up

Runner Up at Diagrammatic Reasoning competition which was conducted as part of SAEINDIA Student Convention 2016-17 held on 25-02-17 & 26-02-17 at Kongu Engineering College, Erode, Tamil Nadu.

CANSAT 2016

Satellite Building Competition - Runner Up

Runner Up at satellite building workshop which was held at TKMCE, Kollam from 9-04-2016 to 10-04-2016.

Certificates

Professional certifications and academic workshops

Hello (Real) World with ROS - Robot Operating System

EDX

August 2024

View Certificate

Automated and Connected Driving Challenges

EDX

August 2023

View Certificate

Mastering Programming with MATLAB

Coursera

December 2020

View Certificate

Machine Learning

Coursera

July 2020

View Certificate

Python for Everybody

Coursera (5 Course Specialization)

June 2020

View Certificate

A Hands-on Introduction to Engineering Simulation by Cornell University on EDX

EDX

August 2019

View Certificate

Computer Numeric Control of Machine Tools and Processes

NPTEL

April 2018

View Certificate

Product Design in Autodesk Fusion 360 from idea to prototype

Udemy

June 2017

View Certificate

Get In Touch

Let's discuss about simulation development, XR development, robotics, future possibilities or just a normal chat